Google Classroom
Google Classroom
GeoGebra
GeoGebra Classroom
Kirjaudu
Haku
Google Classroom
Google Classroom
GeoGebra
GeoGebra Classroom
Luonnos
MMT: Synthesis of Mechanisms
Synthesis of two angular follower's position with no quick return for a rocker's path ϴ4
Synthesis of two angular positions with no Quick Return
Synthesis of two positions for the coupler
Synthesis of a four bar for 3 posess
Synthesis of two angular position follower with Quick Retu
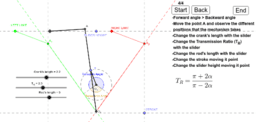
Synthesis of a slider crank with quick return
Synthesis of a Double 4-bar Quick Return
Synthesis of a 6 bar quick return slider crank
Synthesis of a Quick Return Mechanism
Synthesis of trajectory generation for 3 points in specified
Synthesis of 4 bar for 3 coupler's points
Single dwell with dyad
Single Dwell Mechanism with slider
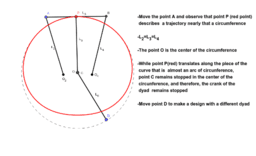
Double rocker mechanism with dyad
MMT: Synthesis of Mechanisms
Tekijä:
Andereguillor
Synthesis of two angular follower's position with no quick return for a rocker's path ϴ4
Synthesis of two angular positions with no Quick Return
Synthesis of two positions for the coupler
Synthesis of a four bar for 3 posess
Synthesis of two angular position follower with Quick Retu
Synthesis of a slider crank with quick return
Synthesis of a Double 4-bar Quick Return
Synthesis of a 6 bar quick return slider crank
Synthesis of a Quick Return Mechanism
Synthesis of trajectory generation for 3 points in specified
Synthesis of 4 bar for 3 coupler's points
Single dwell with dyad
Single Dwell Mechanism with slider
Double rocker mechanism with dyad
Seuraava
Synthesis of two angular follower's position with no quick return for a rocker's path ϴ4
Uusia resursseja
希尔伯特曲线
What Do You See?
Function art 3D - waiting shed (v2)
Pythagorean Template: Integer Legs
Linear Equation Graphs: Thin Slice
Löydä Materiaaleista
Transformations of Functions
Geometry 2014 Lesson 7c Bisecting Figures
ConsumerData
Percentages(I)
Angle Addition Postulate: Formative Assessment
Löydä aiheita
Trigonometria
Jakauma
Mediaani
Yhdenmuotoiset kolmiot
Neljäkäs